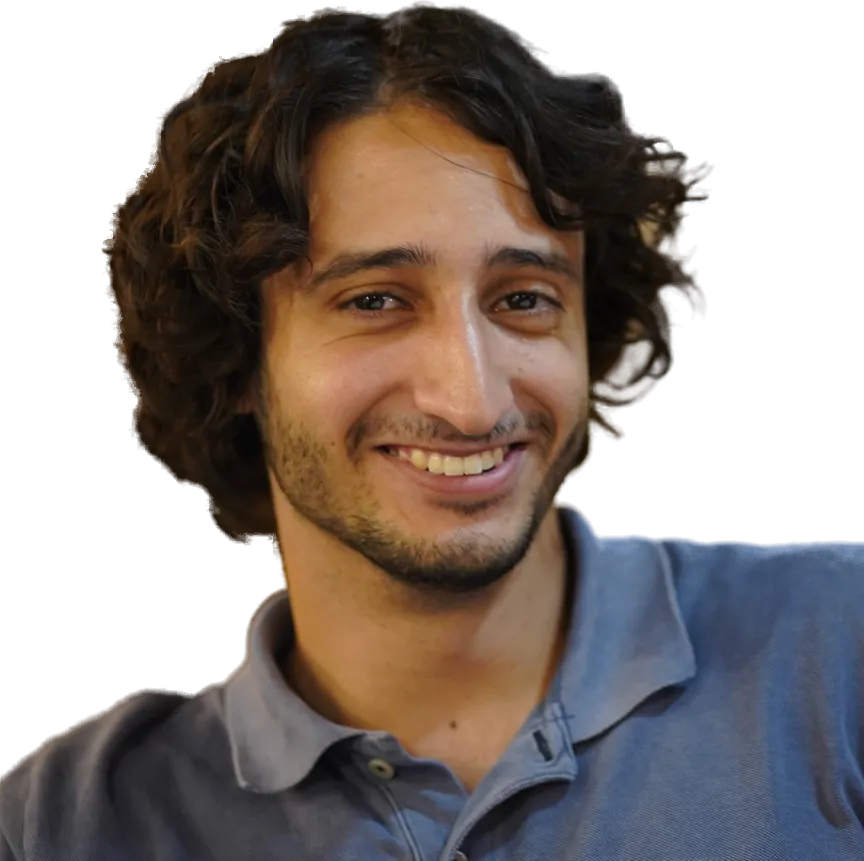
Alexandros Dellios

Alexandros Dellios, smiling, in a blue polo shirt

Robotics M.Sc. · EPFL · Lausanne

Focus areas: Robot learning · Manipulation · Legged locomotion · MPC · Perception

I’m a Master’s student in Robotics at EPFL, focused on robot learning and manipulation. My research goal is to help robots make sense of unstructured, real-world information so they can better assist people in everyday tasks. Right now I research egocentric robot manipulation at BioRob, and I build an Isaac Lab training pipeline for a guide-dog quadruped with the EPFL Student AI Team.

What I’m doing now

Research · robot learning · Lausanne

NOW · RESEARCH · JUL 2026 –

Robots that learn from a human point of view

At EPFL’s Biorobotics Laboratory (BioRob Lab), I research egocentric, data-driven robot manipulation, focusing on bridging the embodiment gap between human demonstrations and robotic execution.

At EPFL’s Biorobotics Laboratory (BioRob Lab), I research egocentric, data-driven robot manipulation: bridging the embodiment gap between human demonstrations and robotic execution.

Graduate Research Assistant · BioRob Lab, EPFL

  • Robot learning
  • Egocentric data
  • Manipulation
  • Embodiment gap

Research in progress. Happy to talk about it in person.

Coming soon · Lab photo
NOW · EPFL STUDENT AI TEAM · FEB 2026 –

A guide-dog quadruped, built from scratch

As a Machine Learning Engineer, I contribute to the ground-up design of a custom quadruped that will act as a guide dog for visually impaired people. I implemented a real-time ROS 2 pipeline and a custom C++ CAN bus interface on NVIDIA Jetson hardware for reliable motor control and state synchronization, and I’m building a simulation pipeline in NVIDIA Isaac Lab to train reinforcement-learning policies for varied terrain.

I contribute to the ground-up design of a custom quadruped that will act as a guide dog for visually impaired people. I built its real-time ROS 2 pipeline and C++ CAN bus interface on NVIDIA Jetson, and I’m building an Isaac Lab pipeline to train its RL policies.

Machine Learning Engineer · EPFL Student AI Team

  • Isaac Lab
  • Reinforcement learning
  • ROS 2
  • C++ CAN bus
  • NVIDIA Jetson
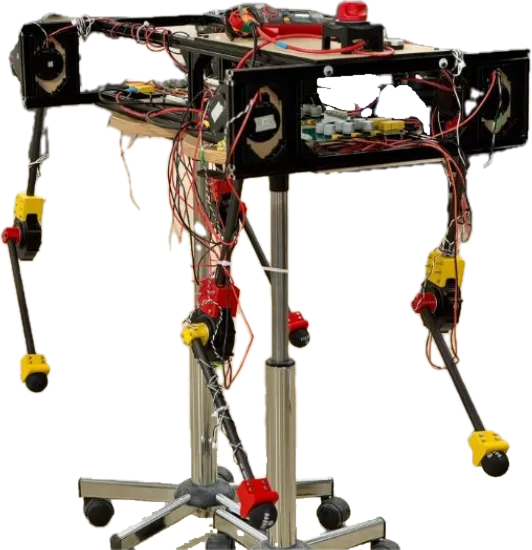
The EPFL Student AI Team’s guide-dog quadruped prototype on its test stand

Selected work

06 projects · 2025–26 · hover to play

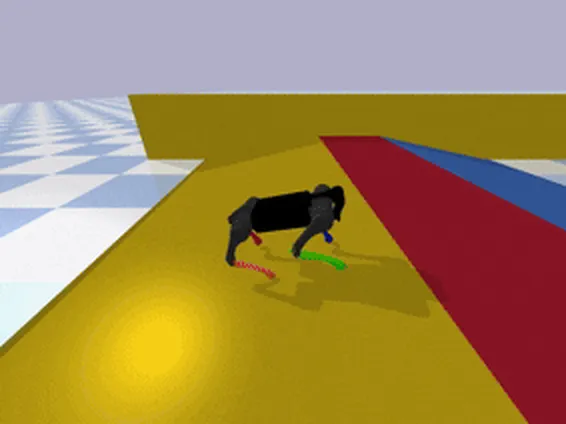
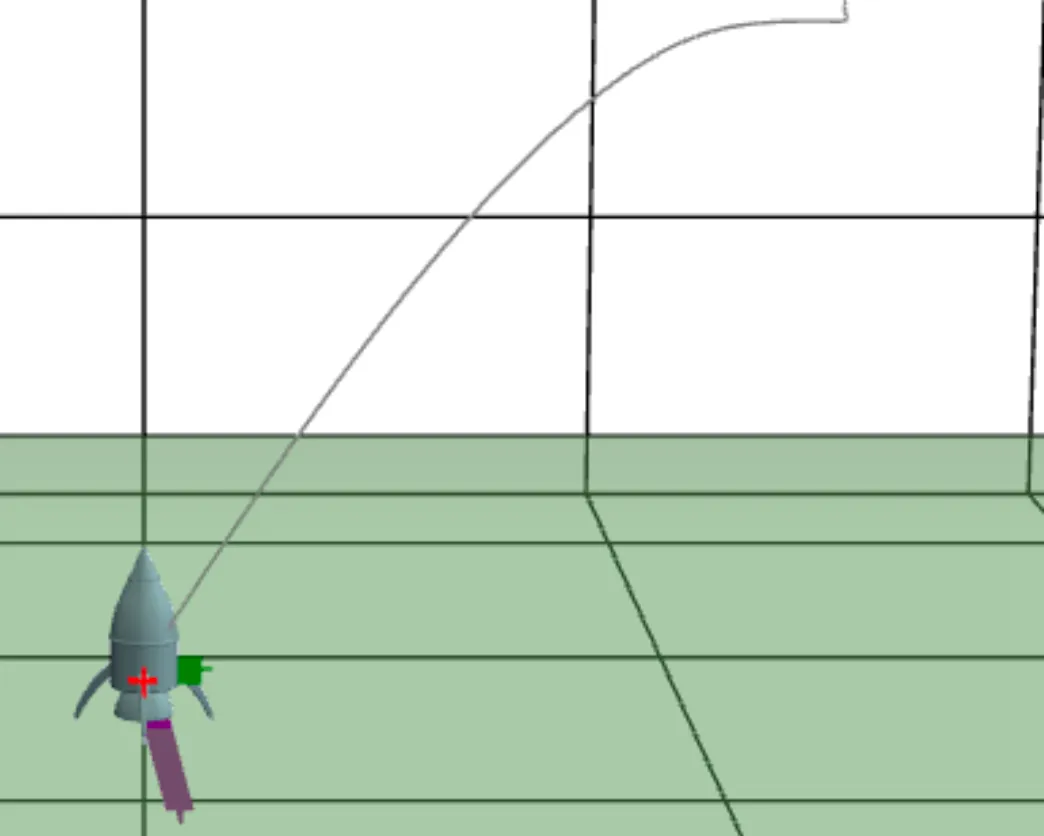
I teach legged robots to walk with reinforcement learning, write controllers that land rockets, and train networks to read a cluttered table.

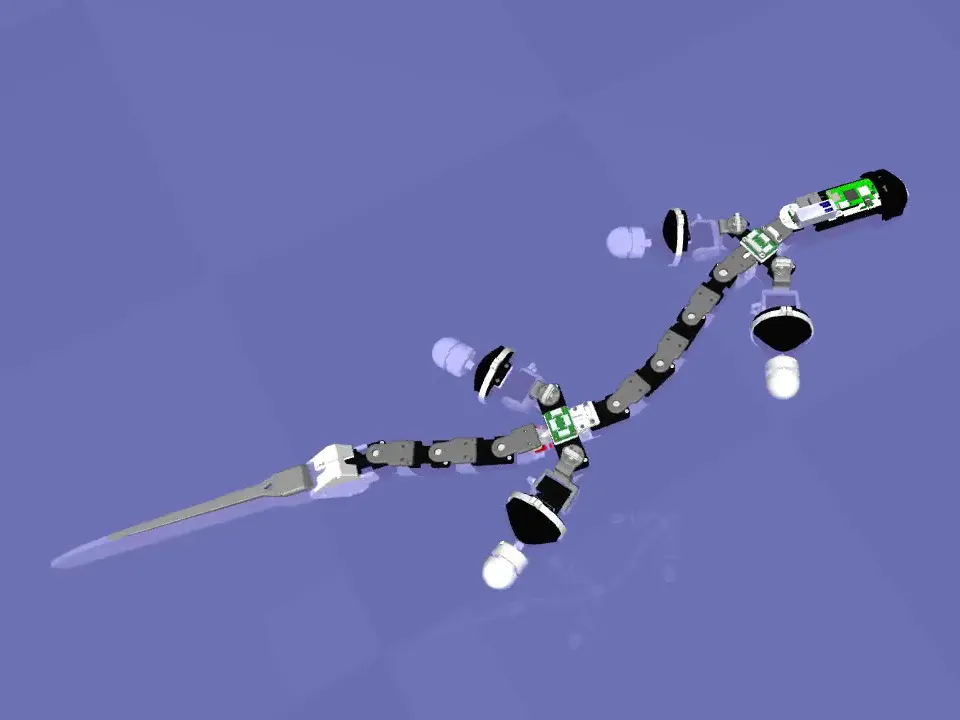
I like controllers that hold up when things go wrong: sensory feedback that keeps a robot swimming through neural damage, a glider that lands precisely in the wind, and a robot that keeps its bearings when its camera goes dark.

Also on the bench: a simulated fruit fly that follows a smell past obstacles, and a C++ simulator for a fleet of cleanup robots.

Smaller and earlier work

  1. 2026

    Fly navigation in NeuroMechFly

    A hierarchical controller steers a simulated fruit fly to an odor source past obstacles, wind, hills and a predator, using simulated vision and smell. My part: posture correction, odor attraction and the movement logic for the first two levels.

    CoBAR course · Team of 3

    Python · MuJoCo · flygym

  2. 2023

    Multi-robot cleanup simulator

    A base station deploys robots with limited turning rates to decontaminate a hazardous zone. I wrote the robot motion controllers, collision geometry and rendering.

    B.Sc. C++ course · Team of 2

    C++17 · GTKmm 4 · Cairo

Experience & education

Experience

  1. Jul 2026 – now

    Graduate Research AssistantBioRob Lab, EPFL

    Researching egocentric data-driven robot manipulation, focusing on bridging the embodiment gap between human demonstrations and robotic execution.

  2. Feb 2026 – now

    Machine Learning EngineerEPFL Student AI Team

    Contributing to the ground-up design and build of a custom quadruped meant to act as a guide dog for the visually impaired. Implemented a real-time ROS 2 pipeline and custom C++ CAN bus interface on NVIDIA Jetson hardware, achieving reliable motor control and state synchronization; building an NVIDIA Isaac Lab simulation pipeline to train RL policies for varied-terrain navigation.

  3. Feb – Oct 2025

    Lead Design & Fabrication EngineerMediacom EPFL

    Won a competitive design pitch for the official EPFL Doctor Honoris Causa Award out of 12 proposals and took full ownership from concept to physical fabrication, partnering with PhD researchers and the Mediacom team to meet the award’s strict design standards. The award was presented to Marco Odermatt and others.

Education

  1. 2025 – 2028

    M.Sc. RoboticsEPFL

    Master of Science in Robotics-Engineering, expected 2028. Courses include Legged Robots, Model Predictive Control, Basics of Mobile Robotics, Computational Motor Control, Reinforcement Learning and Deep Learning.

  2. 2022 – 2025

    B.Sc. Micro-EngineeringEPFL

    Bachelor of Science in Micro-Engineering.

The toolbox

From the CV and projects · linked to proof

  • Learning & vision

    • Reinforcement learning (PPO, SAC)
    • Domain randomization
    • Deep learning (data augmentation, debiasing)
    • PyTorch
    • JAX
    • TensorFlow
    • DeepSpeed
    • OpenCV

    Seen in Quadruped, Glider, Uno

  • Control & estimation

    • Model predictive control (linear, tube, nonlinear)
    • Extended Kalman filter
    • Central pattern generators
    • Hardware–software co-design
    • CasADi

    Seen in Rocket, Thymio, Polymander, Glider

  • Simulation & ROS

    • Isaac Lab
    • Isaac Sim
    • MuJoCo
    • PyBullet
    • ROS 2 Jazzy

    Seen in Quadruped, Polymander

  • Hardware & embedded

    • NVIDIA Jetson (Orin Nano)
    • CAN bus
    • STM32
    • ESP32
    • RTOS
  • CAD & fabrication

    • Fusion 360
    • CATIA
    • KiCad
    • 3D printing
    • Machining (lathe, milling)
  • Code & tools

    • Python
    • C++
    • C
    • CUDA
    • Assembly
    • Linux
    • Git
    • Docker
    • HPC / GPU clusters